Sonnenfinsternis
Angelegt Mittwoch 11 November 2026
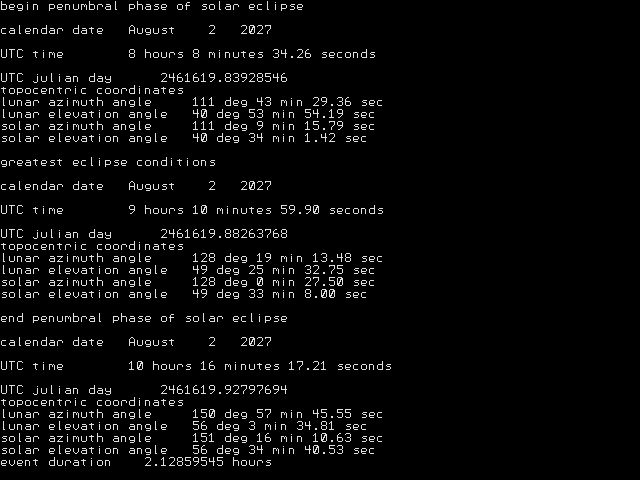
Die nächste Sonnenfinsternis (hier im Süden Deutschlands 50%) findet am 2. August 2027 um 9 Uhr UTC statt.
Ich habe die genauen Daten mit dem CMM2 und dem Programm solar_eclipse.bas berechnet:
' solar_eclipse.bas July 13, 2018
' local circumstances of solar eclipses
' Micromite eXtreme and Nucleo H743ZI version
'''''''''''''''''''''''''''''''''''''''''''''''''
option default float
option base 1
' dimension global arrays and variables
dim xsl(50), xsr(50), xsa(50), xsb(50)
dim jdleap(28), leapsec(28)
dim month$(12) as string
dim xnut(11, 13), trr, elev_minima
dim jdsaved, jdprint, obslat, obslong, obsalt
dim jdtdbi, i as integer, j as integer
dim cmonth, cday, cyear, ndays, obliq
' global constants
const pi2 = 2.0 * pi, pidiv2 = 0.5 * pi, dtr = pi / 180.0, rtd = 180.0 / pi
const atr = pi / 648000.0, seccon = 206264.8062470964
' equatorial radius of the earth (kilometers)
const reqm = 6378.14
' earth flattening factor (nd)
const flat = 1.0 / 298.257
' astronomical unit (kilometers)
const aunit = 149597870.691
' radius of the sun (kilometers)
const radsun = 696000.0
' radius of the moon (kilometers)
const radmoon = 1738.0
' read solar ephemeris data
for i = 1 to 50
data 403406, 0, 4.721964, 1.621043
data 195207, -97597, 5.937458, 62830.348067
data 119433, -59715, 1.115589, 62830.821524
data 112392, -56188, 5.781616, 62829.634302
data 3891, -1556, 5.5474 , 125660.5691
data 2819, -1126, 1.5120 , 125660.9845
data 1721, -861, 4.1897 , 62832.4766
data 0, 941, 1.163 , 0.813
data 660, -264, 5.415 , 125659.310
data 350, -163, 4.315 , 57533.850
data 334, 0, 4.553 , -33.931
data 314, 309, 5.198 , 777137.715
data 268, -158, 5.989 , 78604.191
data 242, 0, 2.911 , 5.412
data 234, -54, 1.423 , 39302.098
data 158, 0, 0.061 , -34.861
data 132, -93, 2.317 , 115067.698
data 129, -20, 3.193 , 15774.337
data 114, 0, 2.828 , 5296.670
data 99, -47, 0.52 , 58849.27
data 93, 0, 4.65 , 5296.11
data 86, 0, 4.35 , -3980.70
data 78, -33, 2.75 , 52237.69
data 72, -32, 4.50 , 55076.47
data 68, 0, 3.23 , 261.08
data 64, -10, 1.22 , 15773.85
data 46, -16, 0.14 , 188491.03
data 38, 0, 3.44 , -7756.55
data 37, 0, 4.37 , 264.89
data 32, -24, 1.14 , 117906.27
data 29, -13, 2.84 , 55075.75
data 28, 0, 5.96 , -7961.39
data 27, -9, 5.09 , 188489.81
data 27, 0, 1.72 , 2132.19
data 25, -17, 2.56 , 109771.03
data 24, -11, 1.92 , 54868.56
data 21, 0, 0.09 , 25443.93
data 21, 31, 5.98 , -55731.43
data 20, -10, 4.03 , 60697.74
data 18, 0, 4.27 , 2132.79
data 17, -12, 0.79 , 109771.63
data 14, 0, 4.24 , -7752.82
data 13, -5, 2.01 , 188491.91
data 13, 0, 2.65 , 207.81
data 13, 0, 4.98 , 29424.63
data 12, 0, 0.93 , -7.99
data 10, 0, 2.21 , 46941.14
data 10, 0, 3.59 , -68.29
data 10, 0, 1.50 , 21463.25
data 10, -9, 2.55 , 157208.40
' read subset of IAU2000 nutation data
for j = 1 to 13
read xnut(i, j)
next i
data 0, 0, 0, 0, 1, -172064161, -174666, 92052331, 9086, 33386, 15377
data 0, 0, 2, -2, 2, -13170906, -1675, 5730336, -3015, -13696, -4587
data 0, 0, 2, 0, 2, -2276413, -234, 978459, -485, 2796, 1374
data 0, 0, 0, 0, 2, 2074554, 207, -897492, 470, -698, -291
data 0, 1, 0, 0, 0, 1475877, -3633, 73871, -184, 11817, -1924
data 0, 1, 2, -2, 2, -516821, 1226, 224386, -677, -524, -174
data 1, 0, 0, 0, 0, 711159, 73, -6750, 0, -872, 358
data 0, 0, 2, 0, 1, -387298, -367, 200728, 18, 380, 318
data 1, 0, 2, 0, 2, -301461, -36, 129025, -63, 816, 367
data 0, -1, 2, -2, 2, 215829, -494, -95929, 299, 111, 132
data 0, 0, 2, -2, 1, 128227, 137, -68982, -9, 181, 39
data -1, 0, 2, 0, 2, 123457, 11, -53311, 32, 19, -4
data -1, 0, 0, 2, 0, 156994, 10, -1235, 0, -168, 82
' read leap second data
for i = 1 to 28
data 2441317.5, 10.0
data 2441499.5, 11.0
data 2441683.5, 12.0
data 2442048.5, 13.0
data 2442413.5, 14.0
data 2442778.5, 15.0
data 2443144.5, 16.0
data 2443509.5, 17.0
data 2443874.5, 18.0
data 2444239.5, 19.0
data 2444786.5, 20.0
data 2445151.5, 21.0
data 2445516.5, 22.0
data 2446247.5, 23.0
data 2447161.5, 24.0
data 2447892.5, 25.0
data 2448257.5, 26.0
data 2448804.5, 27.0
data 2449169.5, 28.0
data 2449534.5, 29.0
data 2450083.5, 30.0
data 2450630.5, 31.0
data 2451179.5, 32.0
data 2453736.5, 33.0
data 2454832.5, 34.0
DATA 2456109.5, 35.0
data 2457204.5, 36.0
data 2457754.5, 37.0
' calendar months
month$(1) = "January"
month$(2) = "February"
month$(3) = "March"
month$(4) = "April"
month$(5) = "May"
month$(6) = "June"
month$(7) = "July"
month$(8) = "August"
month$(9) = "September"
month$(10) = "October"
month$(11) = "November"
month$(12) = "December"
print " "
print "program solar_eclipse"
print "====================="
' request initial calendar date (month, day, year)
getdate(cmonth, cday, cyear)
' request observer coordinates
print " "
observer(obslat, obslong, obsalt)
' initial utc julian day
julian(cmonth, cday, cyear, jdutc)
' compute initial tdb julian date
utc2tdb(jdutc, jdtdb)
jdtdbi = jdtdb
' search duration (days)
print " "
print "please input the search duration in days"
input ndays
print " "
print "searching for solar eclipse ..."
print " "
' define search parameters
ti = 0.0
tf = ndays
dt = 0.25
dtsml = 0.1
' find eclipse conditions
ecl_event(ti, tf, dt, dtsml)
save png "A:/sonnenfinsternis.png"
end
'''''''''''''''''''
'''''''''''''''''''
sub sefunc(x, fx)
' solar eclipse objective function
' input
' x = elapsed simulation time (days)
' output
' fx = objective function at x
'''''''''''''''''''''''''''''''''''
local rsun(3), rmoon(3)
local rtmoon(3)
local rm2s(3)
local uaxis(3)
local um2o(3)
local dvec(5)
LOCAL jdtdb, jdutc
local cpsi, pangle
LOCAL rm2smag, gast
local rtmmoon, psi
local i as integer
' current tdb julian date
jdtdb = jdtdbi + x
' calculate geocentric position vector of the moon (km)
moon(jdtdb, rmoon())
' calculate geocentric position vector of the sun (km)
sun(jdtdb, rsun())
' calculate moon-to-sun position vector (km)
for i = 1 to 3
' compute topocentric coordinates of the moon
tdb2utc(jdtdb, jdutc)
gast2(jdutc, gast)
eci2topo(gast, rmoon(), dvec())
rtmoon(1) = dvec(3)
rtmoon(2) = dvec(4)
rtmoon(3) = dvec(5)
rtmmoon = vecmag(rtmoon())
' current topocentric elevation of the moon (radians)
elev_minima = dvec(2)
' compute shadow axis unit position vector
rm2smag = vecmag(rm2s())
for i = 1 to 3
' compute moon-to-observer unit position vector
for i = 1 to 3
' calculate penumbra shadow angle
pangle = asin(radmoon / rtmmoon) + asin((radsun + radmoon) / rm2smag)
' compute separation angle between anti-sun and moon-to-observer vectors
cpsi = vdot(uaxis(), um2o())
psi = acos(cpsi)
' compute objective function
fx = psi - pangle
end sub
'''''''''''''''''''''''''''''''''''
'''''''''''''''''''''''''''''''''''
sub ecl_event (ti, tf, dt, dtsml)
' predict solar eclipse events
' input
' ti = initial simulation time
' tf = final simulation time
' dt = step size used for bounding minima
' dtsml = small step size used to determine whether
' the function is increasing or decreasing
'''''''''''''''''''''''''''''''''''''''''''''''''''''''
LOCAL tolm, iend as integer
local fmin1, tmin1
LOCAL ftemp, df, dflft
local el, er
LOCAL t, ft
local iter1 as integer, iter2 as integer
local iter3 as integer
' initialization
tolm = 1.0e-6
iend = 0
' check the initial time for a minimum
sefunc(ti, fmin1)
tmin1 = ti
sefunc(ti + dtsml, ftemp)
df = ftemp - fmin1
dflft = df
el = ti
er = el
t = ti
' if the slope is positive and the minimum is
' negative, calculate event conditions at the initial time
if (df > 0.0 and fmin1 < 0.0) then
for iter1 = 1 to 100000
' find where function first starts decreasing
if (df <= 0.0) then
t = t + dt
if (t >= tf) then
sefunc(tf, fmin1)
sefunc(tf - dtsml, ftemp)
df = fmin1 - ftemp
if (df < 0.0) then
' calculate the event conditions at the final
' simulation time
end if
if (dflft > 0.0) then exit for
er = tf
iend = 1
sefunc(t, ft)
sefunc(t - dtsml, ftemp)
df = ft - ftemp
next iter2
' first starts increasing
el = t
dflft = df
t = t + dt
if (t >= tf) then
sefunc(tf, fmin1)
sefunc(tf - dtsml, ftemp)
df = fmin1 - ftemp
if (df < 0.0) then
' calculate the event conditions at the final
' simulation time
end if
if (dflft > 0.0) then exit sub
er = tf
iend = 1
sefunc(t, ft)
sefunc(t - dtsml, ftemp)
df = ft - ftemp
if (df > 0.0) then exit for
next iter3
er = t
el = er
dflft = df
' elevation angle of the moon is positive,
' calculate event conditions for this minimum
events1(ti, tf, tmin1)
t = trr
end if
end sub
''''''''''''''''''''''''''''
''''''''''''''''''''''''''''
sub events1 (ti, tf, topt)
' compute and display eclipse events
' input
' ti = initial simulation time
' tf = final simulation time
' topt = extrema time
''''''''''''''''''''''''''
' define root-bracketing and root-finding control parameters
LOCAL factor = 0.25 ' geometric acceleration factor
LOCAL dxmax = 600.0 / 86400.0 ' rectification interval
LOCAL rtol = 1.0e-8 ' root-finding convergence tolerance
LOCAL t1in, t2in
local t1out, t2out
LOCAL troot, froot, jdate
' compute and display event start conditions
t1in = topt
t2in = t1in - 30.0 / 86400.0
broot(t1in, t2in, factor, dxmax, t1out, t2out)
brent(t1out, t2out, rtol, troot, froot)
' set to initial time if before ti
if (troot < ti) then
sefunc(ti, froot)
jdate = jdtdbi + troot
eclprint(1, jdate)
' compute and display greatest eclipse conditions
jdate = jdtdbi + topt
eclprint(2, jdate)
' compute and display event end conditions
t2in = t1in + 30.0 / 86400.0
broot(t1in, t2in, factor, dxmax, t1out, t2out)
brent(t1out, t2out, rtol, troot, froot)
' set to final time if after tf
if (troot > tf) then
sefunc(tf, froot)
jdate = jdtdbi + troot
eclprint(3, jdate)
' save current value of root
trr = troot
END sub
''''''''''''''''''''''''''''
''''''''''''''''''''''''''''
sub eclprint(iflag, jdtdb)
' print solar eclipse conditions
''''''''''''''''''''''''''''''''''''
local rsun(3), rmoon(3), dvec(5)
LOCAL jdutc, dms$ as string
local deltat, gast
if (iflag = 1) then
'PRINT " "
print "begin penumbral phase of solar eclipse"
PRINT " "
jdprint = jdtdb
if (iflag = 2) then
'PRINT " "
print "greatest eclipse conditions"
PRINT " "
if (iflag = 3) then
'PRINT " "
print "end penumbral phase of solar eclipse"
PRINT " "
' print UTC julian date
tdb2utc(jdtdb, jdutc)
jd2str(jdutc)
PRINT " "
print "UTC julian day ", str$(jdutc, 0, 8)
' compute and display topocentric coordinates of the moon
gast2(jdutc, gast)
moon(jdtdb, rmoon())
eci2topo(gast, rmoon(), dvec())
'PRINT " "
print "topocentric coordinates"
'PRINT " "
deg2str(rtd * dvec(1), dms$)
print "lunar azimuth angle ", dms$
'PRINT " "
deg2str(rtd * dvec(2), dms$)
print "lunar elevation angle ", dms$
' compute and display topocentric coordinates of the sun
sun(jdtdb, rsun())
eci2topo(gast, rsun(), dvec())
'PRINT " "
deg2str(rtd * dvec(1), dms$)
print "solar azimuth angle ", dms$
'PRINT " "
deg2str(rtd * dvec(2), dms$)
print "solar elevation angle ", dms$
' determine and display event duration
if (iflag = 3) then
end if
END sub
'''''''''''''''''''''
'''''''''''''''''''''
sub sun(jd, rsun())
' precision ephemeris of the Sun
' input
' jd = julian ephemeris day
' output
' rlsun = ecliptic longitude of the sun
' (0 <= rlsun <= 2 pi)
' rasc = right ascension of the Sun (radians)
' (0 <= rasc <= 2 pi)
' decl = declination of the Sun (radians)
' (-pi/2 <= decl <= pi/2)
''''''''''''''''''''''''''''''''''''''
local u, a1, a2, psi, deps, meps, eps, seps, ceps
local dl, dr, w, srl, crl, srb, crb, sra, cra
u = (jd - 2451545.0) / 3652500.0
' compute nutation in longitude
a1 = 2.18 + u * (-3375.7 + u * 0.36)
a2 = 3.51 + u * (125666.39 + u * 0.1)
psi = 0.0000001 * (-834.0 * sin(a1) - 64.0 * sin(a2))
' compute nutation in obliquity
deps = 0.0000001 * u * (-226938 + u * (-75 + u * (96926 + u * (-2491 - u * 12104))))
meps = 0.0000001 * (4090928.0 + 446.0 * cos(a1) + 28.0 * cos(a2))
eps = meps + deps
obliq = eps
seps = sin(eps)
ceps = cos(eps)
dl = 0.0
dr = 0.0
for i% = 1 to 50
dl = dl + xsl(i%) * sin(w)
if (xsr(i%) <> 0.0) then
dr = dr + xsr(i%) * cos(w)
end if
dl = modulo(dl * 0.0000001 + 4.9353929 + 62833.196168 * u)
dr = 149597870.691 * (dr * 0.0000001 + 1.0001026)
rlsun = modulo(dl + 0.0000001 * (-993.0 + 17.0 * cos(3.1 + 62830.14 * u)) + psi)
rb = 0.0
' compute geocentric declination and right ascension
crl = cos(rlsun)
srl = sin(rlsun)
crb = cos(rb)
srb = sin(rb)
decl = asin(ceps * srb + seps * crb * srl)
sra = -seps * srb + ceps * crb * srl
cra = crb * crl
rasc = atan3(sra, cra)
' geocentric equatorial position vector of the Sun (kilometers)
rsun(1) = dr * cos(rasc) * cos(decl)
rsun(2) = dr * sin(rasc) * cos(decl)
rsun(3) = dr * sin(decl)
end sub
''''''''''''''''''''''''''''''''''''
''''''''''''''''''''''''''''''''''''
sub eci2topo(gast, robj(), dvec())
' convert eci position vector to topocentric coordinates
' input
' gast = Greenwich apparent sidereal time (radians)
' robj = eci position vector of object (kilometers)
' output
' dvec(1) = topocentric azimuth (radians)
' dvec(2) = topocentric elevation (radians)
' dvec(3) = x-component of topocentric position vector
' dvec(4) = y-component of topocentric position vector
' dvec(5) = z-component of topocentric position vector
'''''''''''''''''''''''''''''''''''''''''''''''''''''''''''
local rsite(3), rhoijk(3), rhohatijk(3), rhohatsez(3)
local i as integer, tmatrix(3, 3)
LOCAL obslst, srange, sobslat
local cobslat, sobslst, cobslst
local elevation, azimuth
' observer local sidereal time
obslst = modulo(gast + obslong)
gsite(obslst, rsite())
' eci vector from observer to moon
for i = 1 to 3
' observer-to-object slant range
srange = vecmag(rhoijk())
' compute topocentric unit pointing vector
uvector(rhoijk(), rhohatijk())
' compute eci-to-sez transformation matrix
sobslat = sin(obslat)
cobslat = cos(obslat)
sobslst = sin(obslst)
cobslst = cos(obslst)
tmatrix(1, 1) = sobslat * cobslst
tmatrix(1, 2) = sobslat * sobslst
tmatrix(1, 3) = -cobslat
tmatrix(2, 1) = -sobslst
tmatrix(2, 2) = cobslst
tmatrix(2, 3) = 0.0
tmatrix(3, 1) = cobslat * cobslst
tmatrix(3, 2) = cobslat * sobslst
tmatrix(3, 3) = sobslat
' compute sez coordinates
matxvec(tmatrix(), rhohatijk(), rhohatsez())
' topocentric elevation (radians)
elevation = asin(rhohatsez(3))
' topocentric azimuth (radians)
azimuth = atan3(rhohatsez(2), -rhohatsez(1))
' load information array
dvec(1) = azimuth
dvec(2) = elevation
dvec(3) = rhoijk(1)
dvec(4) = rhoijk(2)
dvec(5) = rhoijk(3)
END sub
''''''''''''''''''''''''''
''''''''''''''''''''''''''
sub moon(jdate, rmoon())
' geocentric position of the moon subroutine
' input
' jdate = tdb julian day
' output
' rmoon = eci position vector of the moon (kilometers)
'''''''''''''''''''''''''''''''''''''''''''''''''''''''''''
local t1, t2, t3
local t4, dpsi, deps
LOCAL ll, d, lp
local l, f, t
LOCAL ve, ma, ju
local rm, dv, pl
local plat, plon
LOCAL a, b
local rasc, decl, obliq
' get nutations and obliquity
obliq_lp(jdate, dpsi, deps, obliq)
' evaluate lunar ephemeris
t1 = (jdate - 2451545.0) / 36525.0
t2 = t1 * t1
t3 = t1 * t1 * t1
t4 = t1 * t1 * t1 * t1
' calculate fundamental arguments (radians)
ll = dtr * (218 + (18 * 60 + 59.95571) / 3600)
ll = modulo(ll + atr * (1732564372.83264 * t1 - 4.7763 * t2 + .006681 * t3 - 0.00005522 * t4))
d = dtr * (297 + (51 * 60 + .73512) / 3600)
d = modulo(d + atr * (1602961601.4603 * t1 - 5.8681 * t2 + .006595 * t3 - 0.00003184 * t4))
lp = dtr * (357 + (31 * 60 + 44.79306) / 3600)
lp = modulo(lp + atr * (129596581.0474 * t1 - .5529 * t2 + 0.000147 * t3))
l = dtr * (134 + (57 * 60 + 48.28096) / 3600)
l = modulo(l + atr * (1717915923.4728 * t1 + 32.3893 * t2 + .051651 * t3 - 0.0002447 * t4))
f = dtr * (93 + (16 * 60 + 19.55755) / 3600)
f = modulo(f + atr * (1739527263.0983 * t1 - 12.2505 * t2 - .001021 * t3 + 0.00000417 * t4))
t = dtr * (100 + (27 * 60 + 59.22059) / 3600)
t = modulo(t + atr * (129597742.2758 * t1 - .0202 * t2 + .000009 * t3 + 0.00000015 * t4))
ve = dtr * (181 + (58 * 60 + 47.28305) / 3600)
ve = modulo(ve + atr * 210664136.43355 * t1)
ma = dtr * (355 + (25 * 60 + 59.78866) / 3600)
ma = modulo(ma + atr * 68905077.59284 * t1)
ju = dtr * (34 + (21 * 60 + 5.34212) / 3600)
ju = modulo(ju + atr * 10925660.42861 * t1)
' compute geocentric distance (kilometers)
' a(c,0,r) series
rm = 385000.52899
rm = rm - 20905.35504 * sin(l + pidiv2)
rm = rm - 3699.11092 * sin(2 * d - l + pidiv2)
rm = rm - 2955.96756 * sin(2 * d + pidiv2)
rm = rm - 569.92512 * sin(2 * l + pidiv2)
rm = rm + 246.15848 * sin(2 * d - 2 * l + pidiv2)
rm = rm - 204.58598 * sin(2 * d - lp + pidiv2)
rm = rm - 170.73308 * sin(2 * d + l + pidiv2)
rm = rm - 152.13771 * sin(2 * d - lp - l + pidiv2)
rm = rm - 129.62014 * sin(lp - l + pidiv2)
rm = rm + 108.7427 * sin(d + pidiv2)
rm = rm + 104.75523 * sin(lp + l + pidiv2)
rm = rm + 79.66056 * sin(l - 2 * f + pidiv2)
rm = rm + 48.8883 * sin(lp + pidiv2)
rm = rm - 34.78252 * sin(4 * d - l + pidiv2)
rm = rm + 30.82384 * sin(2 * d + lp + pidiv2)
rm = rm + 24.20848 * sin(2 * d + lp - l + pidiv2)
rm = rm - 23.21043 * sin(3 * l + pidiv2)
rm = rm - 21.63634 * sin(4 * d - 2 * l + pidiv2)
rm = rm - 16.67471 * sin(d + lp + pidiv2)
rm = rm + 14.40269 * sin(2 * d - 3 * l + pidiv2)
rm = rm - 12.8314 * sin(2 * d - lp + l + pidiv2)
rm = rm - 11.64995 * sin(4 * d + pidiv2)
rm = rm - 10.44476 * sin(2 * d + 2 * l + pidiv2)
rm = rm + 10.32111 * sin(2 * d - 2 * f + pidiv2)
rm = rm + 10.0562 * sin(2 * d - lp - 2 * l + pidiv2)
rm = rm - 9.88445 * sin(2 * d - 2 * lp + pidiv2)
rm = rm + 8.75156 * sin(2 * d - l - 2 * f + pidiv2)
rm = rm - 8.37911 * sin(d - l + pidiv2)
rm = rm - 7.00269 * sin(lp - 2 * l + pidiv2)
rm = rm + 6.322 * sin(d + l + pidiv2)
rm = rm + 5.75085 * sin(lp + 2 * l + pidiv2)
rm = rm - 4.95013 * sin(2 * d - 2 * lp - l + pidiv2)
rm = rm - 4.42118 * sin(2 * l - 2 * f + pidiv2)
rm = rm + 4.13111 * sin(2 * d + l - 2 * f + pidiv2)
rm = rm - 3.95798 * sin(4 * d - lp - l + pidiv2)
rm = rm + 3.25824 * sin(3 * d - l + pidiv2)
rm = rm - 3.1483 * sin(2 * f + pidiv2)
rm = rm + 2.61641 * sin(2 * d + lp + l + pidiv2)
rm = rm + 2.35363 * sin(2 * d + 2 * lp - l + pidiv2)
rm = rm - 2.11713 * sin(2 * lp - l + pidiv2)
rm = rm - 1.89704 * sin(4 * d - lp - 2 * l + pidiv2)
rm = rm - 1.73853 * sin(d - 2 * l + pidiv2)
rm = rm - 1.57139 * sin(4 * d - lp + pidiv2)
rm = rm - 1.42255 * sin(4 * d + l + pidiv2)
rm = rm - 1.41893 * sin(3 * d + pidiv2)
rm = rm + 1.16553 * sin(2 * lp + l + pidiv2)
rm = rm - 1.11694 * sin(4 * l + pidiv2)
rm = rm + 1.06567 * sin(2 * lp + pidiv2)
rm = rm - .93332 * sin(d + lp + l + pidiv2)
rm = rm + .86243 * sin(3 * d - 2 * l + pidiv2)
rm = rm + .85124 * sin(d + lp - l + pidiv2)
rm = rm - .8488 * sin(2 * d - lp + 2 * l + pidiv2)
rm = rm - .79563 * sin(d - 2 * f + pidiv2)
rm = rm + .77854 * sin(2 * d - 4 * l + pidiv2)
rm = rm + .77404 * sin(2 * d - 2 * l + 2 * f + pidiv2)
rm = rm - .66968 * sin(2 * d + 3 * l + pidiv2)
rm = rm - .65753 * sin(2 * d - 2 * lp + l + pidiv2)
rm = rm + .65706 * sin(2 * d - lp - 2 * f + pidiv2)
rm = rm + .59632 * sin(2 * d - l + 2 * f + pidiv2)
rm = rm + .57879 * sin(4 * d + lp - l + pidiv2)
rm = rm - .51423 * sin(4 * d - 3 * l + pidiv2)
rm = rm - .50792 * sin(4 * d - 2 * f + pidiv2)
rm = rm + .49755 * sin(d - lp + pidiv2)
rm = rm + .49504 * sin(2 * d - lp - 3 * l + pidiv2)
rm = rm + .47262 * sin(2 * d - 2 * l - 2 * f + pidiv2)
rm = rm - .4225 * sin(6 * d - 2 * l + pidiv2)
rm = rm - .42241 * sin(lp - 3 * l + pidiv2)
rm = rm - .41071 * sin(2 * d - 3 * lp + pidiv2)
rm = rm + .37852 * sin(d + 2 * l + pidiv2)
rm = rm + .35508 * sin(lp + 3 * l + pidiv2)
rm = rm + .34302 * sin(2 * d - 2 * lp - 2 * l + pidiv2)
rm = rm + .33463 * sin(lp - l + 2 * f + pidiv2)
rm = rm + .33225 * sin(d + lp - 2 * l + pidiv2)
rm = rm + .32334 * sin(2 * d - lp - l - 2 * f + pidiv2)
rm = rm - .32176 * sin(4 * d - l - 2 * f + pidiv2)
rm = rm - .28663 * sin(6 * d - l + pidiv2)
rm = rm + .28399 * sin(2 * d + 2 * l - 2 * f + pidiv2)
rm = rm - .27904 * sin(4 * d - 2 * lp - l + pidiv2)
rm = rm + .2556 * sin(3 * d - lp - l + pidiv2)
rm = rm - .2481 * sin(lp + l - 2 * f + pidiv2)
rm = rm + .24452 * sin(4 * d + lp + pidiv2)
rm = rm + .23695 * sin(4 * d + lp - 2 * l + pidiv2)
rm = rm - .21258 * sin(3 * d + lp - l + pidiv2)
rm = rm + .21251 * sin(2 * d + lp + 2 * l + pidiv2)
rm = rm + .20941 * sin(2 * d - lp + l - 2 * f + pidiv2)
rm = rm - .20285 * sin(4 * d - lp + l + pidiv2)
rm = rm + .20099 * sin(3 * d - 2 * f + pidiv2)
rm = rm - .18567 * sin(lp - 2 * f + pidiv2)
rm = rm - .18316 * sin(6 * d - 3 * l + pidiv2)
rm = rm + .16857 * sin(2 * d + lp - 3 * l + pidiv2)
rm = rm - .15802 * sin(lp + 2 * f + pidiv2)
rm = rm - .15707 * sin(3 * d - lp + pidiv2)
rm = rm - .14806 * sin(2 * d - 3 * lp - l + pidiv2)
rm = rm + .14763 * sin(2 * d + 2 * lp + pidiv2)
rm = rm + .14368 * sin(2 * d + lp - 2 * l + pidiv2)
rm = rm - .13922 * sin(4 * d + 2 * l + pidiv2)
rm = rm - .13617 * sin(2 * lp - 2 * l + pidiv2)
rm = rm - .13571 * sin(2 * d + lp - 2 * f + pidiv2)
rm = rm - .12805 * sin(4 * d - 2 * lp + pidiv2)
rm = rm + .11411 * sin(d - lp - l + pidiv2)
rm = rm + .10998 * sin(d - lp + l + pidiv2)
rm = rm - .10887 * sin(2 * d + 2 * lp - 2 * l + pidiv2)
rm = rm - .10833 * sin(4 * d - 2 * lp - 2 * l + pidiv2)
rm = rm - .10766 * sin(3 * d + lp + pidiv2)
rm = rm - .10326 * sin(l + 2 * f + pidiv2)
rm = rm - .09938 * sin(d - 3 * l + pidiv2)
rm = rm - .08587 * sin(6 * d + pidiv2)
rm = rm - .07982 * sin(4 * d - 2 * l - 2 * f + pidiv2)
rm = rm - 6.678e-02 * sin(6 * d - lp - 2 * l + pidiv2)
rm = rm - 6.545e-02 * sin(3 * d + l + pidiv2)
rm = rm + .06055 * sin(d + l - 2 * f + pidiv2)
rm = rm - .05904 * sin(d + lp + 2 * l + pidiv2)
rm = rm - .05888 * sin(5 * l + pidiv2)
rm = rm - .0585 * sin(2 * d - lp + 3 * l + pidiv2)
rm = rm - .05789 * sin(4 * d - lp - 2 * f + pidiv2)
rm = rm - .05527 * sin(2 * d + lp + l - 2 * f + pidiv2)
rm = rm + .05293 * sin(3 * d - lp - 2 * l + pidiv2)
rm = rm - .05191 * sin(6 * d - lp - l + pidiv2)
rm = rm + .05072 * sin(2 * lp + 2 * l + pidiv2)
rm = rm - .0502 * sin(lp - 2 * l + 2 * f + pidiv2)
rm = rm - .04843 * sin(3 * d - 3 * l + pidiv2)
rm = rm + .0474 * sin(2 * d - 5 * l + pidiv2)
rm = rm - .04736 * sin(2 * d + lp - l - 2 * f + pidiv2)
rm = rm - .04608 * sin(2 * d - 2 * lp + 2 * l + pidiv2)
rm = rm + .04591 * sin(5 * d - 2 * l + pidiv2)
rm = rm - .04422 * sin(2 * d + 4 * l + pidiv2)
rm = rm - .04316 * sin(4 * d - lp - 3 * l + pidiv2)
rm = rm - .04232 * sin(d - l - 2 * f + pidiv2)
rm = rm - .03894 * sin(3 * lp - l + pidiv2)
rm = rm + .0381 * sin(3 * d + lp - 2 * l + pidiv2)
rm = rm + .03734 * sin(2 * d - lp - l + 2 * f + pidiv2)
rm = rm + .03729 * sin(d + 2 * lp + pidiv2)
rm = rm + .03682 * sin(4 * d + lp + l + pidiv2)
rm = rm + .03379 * sin(d + lp - 2 * f + pidiv2)
rm = rm + .03265 * sin(lp + 2 * l - 2 * f + pidiv2)
rm = rm + .03143 * sin(2 * d + 2 * f + pidiv2)
rm = rm + .03024 * sin(2 * d - lp - 2 * l + 2 * f + pidiv2)
rm = rm - .02948 * sin(d - 2 * lp + pidiv2)
rm = rm - .02939 * sin(4 * d - 4 * l + pidiv2)
rm = rm + .0291 * sin(2 * d - 3 * l - 2 * f + pidiv2)
rm = rm - .02855 * sin(2 * d - 3 * lp + l + pidiv2)
rm = rm + .02839 * sin(2 * d - 2 * lp - 2 * f + pidiv2)
rm = rm - .02698 * sin(4 * d - lp - l - 2 * f + pidiv2)
rm = rm - .02674 * sin(lp - 4 * l + pidiv2)
rm = rm + .02658 * sin(4 * d + 2 * lp - 2 * l + pidiv2)
rm = rm - .02471 * sin(d - l + 2 * f + pidiv2)
rm = rm - .02436 * sin(6 * d - lp - 3 * l + pidiv2)
rm = rm - .02399 * sin(4 * d + lp - 3 * l + pidiv2)
rm = rm + .02368 * sin(d + 3 * l + pidiv2)
rm = rm + .02334 * sin(2 * d - lp - 4 * l + pidiv2)
rm = rm + .02304 * sin(lp + 4 * l + pidiv2)
rm = rm + .02127 * sin(3 * lp + pidiv2)
rm = rm - .02079 * sin(4 * d - lp + 2 * l + pidiv2)
rm = rm - .02008 * sin(2 * d - 3 * l + 2 * f + pidiv2)
' a(p,0,r) series
rm = rm + 1.0587 * sin(2 * t - 2 * ju + 2 * d - l + 90.11969000000001 * dtr)
rm = rm + .72783 * sin(18 * ve - 16 * t - 2 * l + 116.54311 * dtr)
rm = rm + .68256 * sin(18 * ve - 16 * t + 296.54574 * dtr)
rm = rm + .59827 * sin(3 * ve - 3 * t + 2 * d - l + 89.98187 * dtr)
rm = rm + .45648 * sin(ll + l - f + 270.00126 * dtr)
rm = rm + .45276 * sin(ll - l - f + 90.00128 * dtr)
rm = rm + .41011 * sin(2 * t - 3 * ju + 2 * d - l + 280.06924 * dtr)
rm = rm + .20497 * sin(t - ju - 2 * d + 91.79862 * dtr)
rm = rm + .20473 * sin(18 * ve - 16 * t - 2 * d - l + 116.54222 * dtr)
rm = rm + .20367 * sin(18 * ve - 16 * t + 2 * d - l + 296.54299 * dtr)
rm = rm + .16644 * sin(2 * ve - 2 * t - 2 * d + 90.36386 * dtr)
rm = rm + .1578 * sin(4 * t - 8 * ma + 3 * ju + l + 194.98833 * dtr)
rm = rm + .1578 * sin(4 * t - 8 * ma + 3 * ju - l + 14.98841 * dtr)
rm = rm + .15751 * sin(t - ju - 2 * d + l + 91.74578 * dtr)
rm = rm + .1445 * sin(2 * t - 2 * ju - l + 89.97863 * dtr)
rm = rm + .13811 * sin(ve - t - l + 270.00993 * dtr)
rm = rm + .13477 * sin(18 * ve - 16 * t - 2 * d + 116.53978 * dtr)
rm = rm + .12671 * sin(18 * ve - 16 * t + 2 * d - 2 * l + 296.54238 * dtr)
rm = rm + .12666 * sin(t - ju - l + 91.22751 * dtr)
rm = rm + .12362 * sin(ve - t - 2 * d + 269.98523 * dtr)
rm = rm + .12047 * sin(2 * ve - 2 * t + 2 * d - l + 269.99692 * dtr)
rm = rm + .11998 * sin(ve - t + l + 90.01606 * dtr)
rm = rm + .11617 * sin(2 * ve - 2 * t - 2 * d + l + 90.31081 * dtr)
rm = rm + .11256 * sin(4 * t - 8 * ma + 3 * ju + 2 * d - l + 197.11421 * dtr)
rm = rm + .11251 * sin(4 * t - 8 * ma + 3 * ju - 2 * d + l + 17.11263 * dtr)
rm = rm + .11226 * sin(4 * t - 8 * ma + 3 * ju + 2 * d + 196.69224 * dtr)
rm = rm + .11216 * sin(4 * t - 8 * ma + 3 * ju - 2 * d + 16.68897 * dtr)
rm = rm + .10689 * sin(ll + 2 * d - f + 270.00092 * dtr)
rm = rm + .10504 * sin(t - ju + l + 271.06726 * dtr)
rm = rm + .1006 * sin(ve - t - 2 * d + l + 269.98452 * dtr)
rm = rm + 9.932e-02 * sin(3 * ve - 3 * t - l + 90.1054 * dtr)
rm = rm + .09554 * sin(ll - 2 * d - f + 90.00096 * dtr)
rm = rm + .08508 * sin(ll - f + 270.00061 * dtr)
rm = rm + 7.9450e-02 * sin(4 * ve - 4 * t + 2 * d - l + 89.99224 * dtr)
rm = rm + .07725 * sin(2 * t - 3 * ju - l + 280.16516 * dtr)
rm = rm + 7.054e-02 * sin(6 * ve - 8 * t + 2 * d - l + 77.22087 * dtr)
rm = rm + 6.313e-02 * sin(2 * ju - 5 * l + l + 256.56163 * dtr)
' a(p,1,r) series
rm = rm + .51395 * t1 * sin(2 * d - lp + pidiv2)
rm = rm + .38245 * t1 * sin(2 * d - lp - l + pidiv2)
rm = rm + .32654 * t1 * sin(lp - l + pidiv2)
rm = rm + .26396 * t1 * sin(lp + l + 270 * dtr)
rm = rm + .12302 * t1 * sin(lp + 270 * dtr)
rm = rm + .07754 * t1 * sin(2 * d + lp + 270 * dtr)
rm = rm + .06068 * t1 * sin(2 * d + lp - l + 270 * dtr)
rm = rm + .0497 * t1 * sin(2 * d - 2 * lp + pidiv2)
rm = rm + .04194 * t1 * sin(d + lp + pidiv2)
rm = rm + .03222 * t1 * sin(2 * d - lp + l + pidiv2)
rm = rm + .02529 * t1 * sin(2 * d - lp - 2 * l + 270 * dtr)
rm = rm + .0249 * t1 * sin(2 * d - 2 * lp - l + pidiv2)
rm = rm + .00149 * t2 * sin(2 * d - lp + pidiv2)
rm = rm + .00111 * t2 * sin(2 * d - lp - l + pidiv2)
rmm = rm
' compute geocentric ecliptic longitude (arc seconds)
' a(c,0,v) series
dv = 22639.58578 * sin(l)
dv = dv + 4586.4383 * sin(2 * d - l)
dv = dv + 2369.91394 * sin(2 * d)
dv = dv + 769.02571 * sin(2 * l)
dv = dv - 666.4171 * sin(lp)
dv = dv - 411.59567 * sin(2 * f)
dv = dv + 211.65555 * sin(2 * d - 2 * l)
dv = dv + 205.43582 * sin(2 * d - lp - l)
dv = dv + 191.9562 * sin(2 * d + l)
dv = dv + 164.72851 * sin(2 * d - lp)
dv = dv - 147.32129 * sin(lp - l)
dv = dv - 124.98812 * sin(d)
dv = dv - 109.38029 * sin(lp + l)
dv = dv + 55.17705 * sin(2 * d - 2 * f)
dv = dv - 45.0996 * sin(l + 2 * f)
dv = dv + 39.53329 * sin(l - 2 * f)
dv = dv + 38.42983 * sin(4 * d - l)
dv = dv + 36.12381 * sin(3 * l)
dv = dv + 30.77257 * sin(4 * d - 2 * l)
dv = dv - 28.39708 * sin(2 * d + lp - l)
dv = dv - 24.35821 * sin(2 * d + lp)
dv = dv - 18.58471 * sin(d - l)
dv = dv + 17.95446 * sin(d + lp)
dv = dv + 14.53027 * sin(2 * d - lp + l)
dv = dv + 14.3797 * sin(2 * d + 2 * l)
dv = dv + 13.89906 * sin(4 * d)
dv = dv + 13.19406 * sin(2 * d - 3 * l)
dv = dv - 9.67905 * sin(lp - 2 * l)
dv = dv - 9.36586 * sin(2 * d - l + 2 * f)
dv = dv + 8.60553 * sin(2 * d - lp - 2 * l)
dv = dv - 8.45310 * sin(d + l)
dv = dv + 8.05016 * sin(2 * d - 2 * lp)
dv = dv - 7.63015 * sin(lp + 2 * l)
dv = dv - 7.44749 * sin(2 * lp)
dv = dv + 7.37119 * sin(2 * d - 2 * lp - l)
dv = dv - 6.38315 * sin(2 * d + l - 2 * f)
dv = dv - 5.74161 * sin(2 * d + 2 * f)
dv = dv + 4.37401 * sin(4 * d - lp - l)
dv = dv - 3.99761 * sin(2 * l + 2 * f)
dv = dv - 3.20969 * sin(3 * d - l)
dv = dv - 2.91454 * sin(2 * d + lp + l)
dv = dv + 2.73189 * sin(4 * d - lp - 2 * l)
dv = dv - 2.56794 * sin(2 * lp - l)
dv = dv - 2.5212 * sin(2 * d + 2 * lp - l)
dv = dv + 2.48889 * sin(2 * d + lp - 2 * l)
dv = dv + 2.14607 * sin(2 * d - lp - 2 * f)
dv = dv + 1.97773 * sin(4 * d + l)
dv = dv + 1.93368 * sin(4 * l)
dv = dv + 1.87076 * sin(4 * d - lp)
dv = dv - 1.75297 * sin(d - 2 * l)
dv = dv - 1.43716 * sin(2 * d + lp - 2 * f)
dv = dv - 1.37257 * sin(2 * l - 2 * f)
dv = dv + 1.26182 * sin(d + lp + l)
dv = dv - 1.22412 * sin(3 * d - 2 * l)
dv = dv + 1.18683 * sin(4 * d - 3 * l)
dv = dv + 1.177 * sin(2 * d - lp + 2 * l)
dv = dv - 1.16169 * sin(2 * lp + l)
dv = dv + 1.07769 * sin(d + lp - l)
dv = dv + 1.0595 * sin(2 * d + 3 * l)
dv = dv - .99022 * sin(2 * d + l + 2 * f)
dv = dv + .94828 * sin(2 * d - 4 * l)
dv = dv + .75168 * sin(2 * d - 2 * lp + l)
dv = dv - .66938 * sin(lp - 3 * l)
dv = dv - .63521 * sin(4 * d + lp - l)
dv = dv - .58399 * sin(d + 2 * l)
dv = dv - .58331 * sin(d - 2 * f)
dv = dv + .57156 * sin(6 * d - 2 * l)
dv = dv - .56064 * sin(2 * d - 2 * l - 2 * f)
dv = dv - .55692 * sin(d - lp)
dv = dv - .54592 * sin(lp + 3 * l)
dv = dv - .53571 * sin(2 * d - 2 * l + 2 * f)
dv = dv + .4784 * sin(2 * d - lp - 3 * f)
dv = dv - .45379 * sin(2 * d + 2 * l - 2 * f)
dv = dv - .42622 * sin(2 * d - lp - l + 2 * f)
dv = dv + .42033 * sin(4 * f)
dv = dv + .4134 * sin(lp + 2 * f)
dv = dv + .40423 * sin(3 * d)
dv = dv + .39451 * sin(6 * d - l)
dv = dv - .38213 * sin(2 * d - lp + 2 * f)
dv = dv - .37451 * sin(2 * d - lp + l - 2 * f)
dv = dv - .35758 * sin(4 * d + lp - 2 * l)
dv = dv + .34965 * sin(d + lp - 2 * l)
dv = dv + .33979 * sin(2 * d - 3 * lp)
dv = dv - .32866 * sin(3 * l + 2 * f)
dv = dv + .30872 * sin(4 * d - 2 * lp - l)
dv = dv + .30155 * sin(lp - l - 2 * f)
dv = dv + .30086 * sin(4 * d - l - 2 * f)
dv = dv + .2942 * sin(2 * d - 2 * lp - 2 * l)
dv = dv + .29255 * sin(6 * d - 3 * l)
dv = dv - .29022 * sin(2 * d + lp + 2 * l)
' a(p,2,v) series
dv = dv + .00487 * t2 * sin(lp)
dv = dv - .0015 * t2 * sin(2 * d - lp - l + pi)
dv = dv - .0012 * t2 * sin(2 * d - lp + pi)
dv = dv + .00108 * t2 * sin(lp - l)
dv = dv + .0008 * t2 * sin(lp + l)
' a(p,0,v) series
dv = dv + 14.24883 * sin(18 * ve - 16 * t - l + dtr * 26.54261)
dv = dv + 7.06304 * sin(ll - f + dtr * .00094)
dv = dv + 1.14307 * sin(2 * t - 2 * ju + 2 * d - l + dtr * 180.11977)
dv = dv + .901140 * sin(4 * t - 8 * ma + 3 * ju + dtr * 285.98707)
dv = dv + .82155 * sin(ve - t + dtr * 180.00988)
dv = dv + .78811 * sin(18 * ve - 16 * t - 2 * l + dtr * 26.54324)
dv = dv + .7393 * sin(18 * ve - 16 * t + dtr * 26.5456)
dv = dv + .64371 * sin(3 * ve - 3 * t + 2 * d - l + dtr * 179.98144)
dv = dv + .6388 * sin(t - ju + dtr * 1.2289)
dv = dv + .56341 * sin(10 * ve - 3 * t - l + dtr * 333.30551)
dv = dv + .49331 * sin(ll + l - f + .00127 * dtr)
dv = dv + .49141 * sin(ll - l - f + .00127 * dtr)
dv = dv + .44532 * sin(2 * t - 3 * ju + 2 * d - l + 10.07001 * dtr)
dv = dv + .36061 * sin(ll + f + .00071 * dtr)
dv = dv + .34355 * sin(2 * ve - 3 * t + 269.95393 * dtr)
dv = dv + .32455 * sin(t - 2 * ma + 318.13776 * dtr)
dv = dv + .30155 * sin(2 * ve - 2 * t + .20448 * dtr)
dv = dv + .28938 * sin(t + d - f + 95.13523 * dtr)
dv = dv + .28281 * sin(2 * t - 3 * ju + 2 * d - 2 * l + 10.03835 * dtr)
dv = dv + .24515 * sin(2 * t - 2 * ju + 2 * d - 2 * l + .08642 * dtr)
' a(p,1,v) series
dv = dv + 1.6768 * t1 * sin(lp)
dv = dv + .51642 * t1 * sin(2 * d - lp - l + pi)
dv = dv + .41383 * t1 * sin(2 * d - lp + pi)
dv = dv + .37115 * t1 * sin(lp - l)
dv = dv + .2756 * t1 * sin(lp + l)
dv = dv + .25425 * t1 * sin(18 * ve - 16 * t - l + 114.5655 * dtr)
dv = dv + 7.1178e-02 * t1 * sin(2 * d + lp - l)
dv = dv + .06128 * t1 * sin(2 * d + lp)
dv = dv + .04516 * t1 * sin(d + lp + pi)
dv = dv + .04048 * t1 * sin(2 * d - 2 * lp + pi)
dv = dv + .03747 * t1 * sin(2 * lp)
dv = dv + .03707 * t1 * sin(2 * d - 2 * lp - l + pi)
dv = dv + .03649 * t1 * sin(2 * d - lp + l + pi)
dv = dv + .02438 * t1 * sin(lp - 2 * l)
dv = dv + .02165 * t1 * sin(2 * d - lp - 2 * l + pi)
dv = dv + .01923 * t1 * sin(lp + 2 * l)
plon = modulo(ll + atr * dv + dpsi)
' compute geocentric ecliptic latitude (arc seconds)
' a(c,0,u) series
pl = 18461.23868 * sin(f)
pl = pl + 1010.16707 * sin(l + f)
pl = pl + 999.69358 * sin(l - f)
pl = pl + 623.65243 * sin(2 * d - f)
pl = pl + 199.48374 * sin(2 * d - l + f)
pl = pl + 166.5741 * sin(2 * d - l - f)
pl = pl + 117.26069 * sin(2 * d + f)
pl = pl + 61.91195 * sin(2 * l + f)
pl = pl + 33.3572 * sin(2 * d + l - f)
pl = pl + 31.75967 * sin(2 * l - f)
pl = pl + 29.57658 * sin(2 * d - lp - f)
pl = pl + 15.56626 * sin(2 * d - 2 * l - f)
pl = pl + 15.12155 * sin(2 * d + l + f)
pl = pl - 12.09414 * sin(2 * d + lp - f)
pl = pl + 8.86814 * sin(2 * d - lp - l + f)
pl = pl + 7.95855 * sin(2 * d - lp + f)
pl = pl + 7.43455 * sin(2 * d - lp - l - f)
pl = pl - 6.73143 * sin(lp - l - f)
pl = pl + 6.57957 * sin(4 * d - l - f)
pl = pl - 6.46007 * sin(lp + f)
pl = pl - 6.29648 * sin(3 * f)
pl = pl - 5.63235 * sin(lp - l + f)
pl = pl - 5.3684 * sin(d + f)
pl = pl - 5.31127 * sin(lp + l + f)
pl = pl - 5.07591 * sin(lp + l - f)
pl = pl - 4.83961 * sin(lp - f)
pl = pl - 4.80574 * sin(d - f)
pl = pl + 3.98405 * sin(3 * l + f)
pl = pl + 3.67446 + sin(4 * d - f)
pl = pl + 2.99848 * sin(4 * d - l + f)
pl = pl + 2.79864 * sin(l - 3 * f)
pl = pl + 2.41388 * sin(4 * d - 2 * l + f)
pl = pl + 2.18631 * sin(2 * d - 3 * f)
pl = pl + 2.14617 * sin(2 * d + 2 * l - f)
pl = pl + 1.76598 * sin(2 * d - lp + l - f)
pl = pl - 1.62442 * sin(2 * d - 2 * l + f)
pl = pl + 1.5813 * sin(3 * l - f)
pl = pl + 1.51975 * sin(2 * d + 2 * l + f)
pl = pl - 1.51563 * sin(2 * d - 3 * l - f)
pl = pl - 1.31782 * sin(2 * d + lp - l + f)
pl = pl - 1.26427 * sin(2 * d + lp + f)
pl = pl + 1.19187 * sin(4 * d + f)
pl = pl + 1.13461 * sin(2 * d - lp + l + f)
pl = pl + 1.08578 * sin(2 * d - 2 * lp - f)
pl = pl - 1.01938 * sin(l + 3 * f)
pl = pl - .822710 * sin(2 * d + lp + l - f)
pl = pl + .80422 * sin(d + lp - f)
pl = pl + .80259 * sin(d + lp + f)
pl = pl - .79319 * sin(lp - 2 * l - f)
pl = pl - .79101 * sin(2 * d + lp - l - f)
pl = pl - .66741 * sin(d + l + f)
pl = pl + .65022 * sin(2 * d - lp - 2 * l - f)
pl = pl - .63881 * sin(lp + 2 * l + f)
pl = pl + .63371 * sin(4 * d - 2 * l - f)
pl = pl + .59577 * sin(4 * d - lp - l - f)
pl = pl - .58893 * sin(d + l - f)
pl = pl + .47338 * sin(4 * d + l - f)
pl = pl - .42989 * sin(d - l - f)
pl = pl + .41494 * sin(4 * d - lp - f)
pl = pl + .3835 * sin(2 * d - 2 * lp + f)
pl = pl - .35183 * sin(3 * d - f)
pl = pl + .33881 * sin(4 * d - lp - l + f)
pl = pl + .32906 * sin(2 * d - l - 3 * f)
' a(p,0,u) series
pl = pl + 8.04508 * sin(ll + 180.00071 * dtr)
pl = pl + 1.51021 * sin(t + d + 276.68007 * dtr)
pl = pl + .63037 * sin(18 * ve - 16 * t - l + f + 26.54287 * dtr)
pl = pl + .63014 * sin(18 * ve - 16 * t - l - f + 26.54272 * dtr)
pl = pl + .45586 * sin(ll - l + .00075 * dtr)
pl = pl + .41571 * sin(ll + l + 180.00069 * dtr)
pl = pl + .32622 * sin(ll - 2 * f + .00086 * dtr)
pl = pl + .29854 * sin(ll - 2 * d + .00072 * dtr)
' a(p,1,u) series
pl = pl + .0743 * t1 * sin(2 * d - lp - f + pi)
pl = pl + .03043 * t1 * sin(2 * d + lp - f)
pl = pl + .02229 * t1 * sin(2 * d - lp - l + f + pi)
pl = pl + .01999 * t1 * sin(2 * d - lp + f + pi)
pl = pl + .01869 * t1 * sin(2 * d - lp - l - f + pi)
pl = pl + .01696 * t1 * sin(lp - l - f)
pl = pl + .01623 * t1 * sin(lp + f)
plat = atr * pl
' compute geocentric right ascension and declination
a = sin(plon) * cos(obliq) - tan(plat) * sin(obliq)
b = cos(plon)
rasc = atan3(a, b)
decl = asin(sin(plat) * cos(obliq) + cos(plat) * sin(obliq) * sin(plon))
' compute the geocentric position vector of the moon (kilometers)
rmoon(1) = rmm * cos(rasc) * cos(decl)
rmoon(2) = rmm * sin(rasc) * cos(decl)
rmoon(3) = rmm * sin(decl)
end sub
''''''''''''''''''''''''''''''''''''''''
''''''''''''''''''''''''''''''''''''''''
sub obliq_lp(jdate, dpsi, deps, obliq)
' nutations and true obliquity
' input
' jdate = julian date
' output
' dpsi = nutation in longitude in radians
' deps = nutation in obliquity in radians
' obliq = true obliquity of the ecliptic in radians
''''''''''''''''''''''''''''''''''''''''''''''''''''''''
LOCAL t, t2, t3, eqeq
LOCAL th, tl, obm, obt, st
LOCAL tjdh, tjdl
' split the julian date
tjdh = int(jdate)
tjdl = jdate - tjdh
' fundamental time units
th = (tjdh - 2451545.0) / 36525.0
tl = tjdl / 36525.0
t = th + tl
t2 = t * t
t3 = t2 * t
' obtain equation of the equinoxes
eqeq = 0.0
' obtain nutations
nut2000_lp(jdate, dpsi, deps)
' compute mean obliquity of the ecliptic in seconds of arc
obm = 84381.4480 - 46.8150 * t - 0.00059 * t2 + 0.001813 * t3
' compute true obliquity of the ecliptic in seconds of arc
obt = obm + deps
' return elements in radians
deps = atr * deps
dpsi = atr * dpsi
obliq = atr * obt
END sub
'''''''''''''''''''''''''''''''''''
'''''''''''''''''''''''''''''''''''
sub nut2000_lp(jdate, dpsi, deps)
' low precison nutation based on iau 2000a
' this function evaluates a short nutation series and returns approximate
' values for nutation in longitude and nutation in obliquity for a given
' tdb julian date. in this mode, only the largest 13 terms of the iau 2000a
' nutation series are evaluated.
' input
' jdate = tdb julian date
' output
' dpsi = nutation in longitude in arcseconds
' deps = nutation in obliquity in arcseconds
'''''''''''''''''''''''''''''''''''''''''''''''''
LOCAL rev = 360.0 * 3600.0
LOCAL el, elp, f, d, omega
LOCAL i%, arg
LOCAL t = (jdate - 2451545.0) / 36525.0
''''''''''''''''''''''''''''''''''''''''''''''''''''''''''''''''''''''''''''''
' computation of fundamental (delaunay) arguments from simon et al. (1994)
''''''''''''''''''''''''''''''''''''''''''''''''''''''''''''''''''''''''''''''
' mean anomaly of the moon
el = (485868.249036 + t * (1717915923.2178 + t * (31.8792 + t * (0.051635 + t * (-0.00024470)))) mod rev) / seccon
' mean anomaly of the sun
elp = (1287104.79305 + t * (129596581.0481 + t * (-0.5532 + t * (0.000136 + t * (- 0.00001149)))) mod rev) / seccon
' mean argument of the latitude of the moon
f = (335779.526232 + t * (1739527262.8478 + t * (-12.7512 + t * (-0.001037 + t * (0.00000417)))) mod rev) / seccon
' mean elongation of the moon from the sun
d = (1072260.70369 + t * (1602961601.2090 + t * (- 6.3706 + t * (0.006593 + t * (- 0.00003169)))) mod rev) / seccon
' mean longitude of the ascending node of the moon (from simon section 3.4(b.3), precession = 5028.8200 arcsec/cy)
omega = (450160.398036 + t * (- 6962890.5431 + t * (7.4722 + t * (0.007702 + t * (- 0.00005939)))) mod rev) / seccon
dpsi = 0.0
deps = 0.0
' sum nutation series terms
for i% = 13 to 1 step -1
dpsi = (xnut(6, i%) + xnut(7, i%) * t) * sin(arg) + xnut(10, i%) * cos(arg) + dpsi
deps = (xnut(8, i%) + xnut(9, i%) * t) * cos(arg) + xnut(11, i%) * sin(arg) + deps
dpsi = 1.0e-7 * dpsi
deps = 1.0e-7 * deps
' add in out-of-phase component of principal (18.6-year) term
' (to avoid small but long-term bias in results)
dpsi = dpsi + 0.0033 * cos(omega)
deps = deps + 0.0015 * sin(omega)
END sub
''''''''''''''''''''''''''''
''''''''''''''''''''''''''''
sub tdb2utc (jdtdb, jdutc)
' convert TDB julian day to UTC julian day subroutine
' input
' jdtdb = TDB julian day
' output
' jdutc = UTC julian day
'''''''''''''''''''''''''''''
local x1, x2
local xroot, froot
jdsaved = jdtdb
' set lower and upper bounds
x1 = jdsaved - 0.1
x2 = jdsaved + 0.1
' solve for UTC julian day using Brent's method
jbrent(x1, x2, 1.0e-8, xroot, froot)
jdutc = xroot
end sub
''''''''''''''''''''''''''''
''''''''''''''''''''''''''''
sub gsite (angle, rsite())
' ground site position vector
' input
' angle = local sidereal time or east longitude
' (radians; 0 <= angle <= 2*pi)
' input via global
' obslat = geodetic latitude (radians)
' (+north, -south; -pi/2 <= lat <= -pi/2)
' obsalt = geodetic altitude (meters)
' (+ above sea level, - below sea level)
' output
' rsite = ground site position vector (kilometers)
' special notes
' (1) eci coordinates if angle = local sidereal time
' (2) ecf coordinates if angle = east longitude
' (3) geocentric, equatorial coordinates
'''''''''''''''''''''''''''''''''''''''''''''
LOCAL slat, clat
local sangle, cangle
LOCAL b, c, d
slat = sin(obslat)
clat = cos(obslat)
sangle = sin(angle)
cangle = cos(angle)
' compute geodetic constants
b = sqr(1.0 - (2.0 * flat - flat * flat) * slat * slat)
c = reqm / b + 0.001 * obsalt
d = reqm * (1.0 - flat) * (1.0 - flat) / b + 0.001 * obsalt
' compute x, y and z components of position vector (kilometers)
rsite(1) = c * clat * cangle
rsite(2) = c * clat * sangle
rsite(3) = d * slat
END sub
''''''''''''''''''''''''
''''''''''''''''''''''''
sub gast2(jdate, gast)
' greenwich apparent sidereal time
' input
' jdate = julian date
' output
' gast = greenwich apparent sidereal time (radians)
'''''''''''''''''''''''''''''''''''''''''''''''''''''''
LOCAL t, t2, t3, eqeq, dpsi, deps
LOCAL th, tl, obm, obt, st, x
local tjdh as integer, tjdl
tjdh = int(jdate)
tjdl = jdate - tjdh
th = (tjdh - 2451545.0) / 36525
tl = tjdl / 36525.0
t = th + tl
t2 = t * t
t3 = t2 * t
' obtain equation of the equinoxes
eqeq = 0.0
' obtain nutation parameters in seconds of arc
nut2000_lp(jdate, dpsi, deps)
' compute mean obliquity of the ecliptic in seconds of arc
obm = 84381.4480 - 46.8150 * t - 0.00059 * t2 + 0.001813 * t3
' compute true obliquity of the ecliptic in seconds of arc
obliq = obm + deps
' compute equation of the equinoxes in seconds of time
eqeq = (dpsi / 15.0) * cos(obliq / seccon)
st = eqeq - 6.2e-6 * t3 + 0.093104 * t2 + 67310.54841 + 8640184.812866 * tl + 3155760000.0 * tl + 8640184.812866 * th + 3155760000.0 * th
' modulo 24 hours
x = st / 3600.0
gast = x - 24.0 * fix(x / 24.0)
if (gast < 0.0) then
' convert to radians
gast = pi2 * (gast / 24.0)
END sub
''''''''''''''''''''''''''''''''
''''''''''''''''''''''''''''''''
sub getdate (month, day, year)
' interactive request calendar date subroutine
do
print "please input the initial calendar date"
print " "
print "(month [1 - 12], day [1 - 31], year [yyyy])"
print "< for example, october 21, 1986 is input as 10,21,1986 >"
print "< b.c. dates are negative, a.d. dates are positive >"
print "< the day of the month may also include a decimal part >"
print " "
input month, day, year
end sub
'''''''''''''''''''''''''''''''''''''''
'''''''''''''''''''''''''''''''''''''''
sub observer(obslat, obslong, obsalt)
' interactive request of latitude, longitude and altitude subroutine
' output
' obslat = latitude (radians)
' obslong = longitude (radians)
' obsalt = altitude (meters)
''''''''''''''''''''''''''''''''''
do
print "(degrees [-90 to +90], minutes [0 - 60], seconds [0 - 60])"
print "(north latitudes are positive, south latitudes are negative)"
input obslat.deg$, obslat.min, obslat.sec
if (left$(obslat.deg$, 2) = "-0") then
do
print "please input the geographic longitude of the observer"
print "(degrees [0 - 360], minutes [0 - 60], seconds [0 - 60])"
print "(east longitude is positive, west longitude is negative)"
input obslong.deg$, obslong.min, obslong.sec
if (left$(obslong.deg$, 2) = "-0") then
print " "
print "please input the altitude of the observer (meters)"
print "(positive above sea level, negative below sea level)"
input obsalt
end sub
''''''''''''''''''''''''''''''''''''
''''''''''''''''''''''''''''''''''''
sub minima(a, b, tolm, xmin, fmin)
' one-dimensional minimization
' Brent's method
' input
' a = initial x search value
' b = final x search value
' tolm = convergence criterion
' output
' xmin = minimum x value
' note
' user-defined objective subroutine
' coded as usr_func(x, fx)
' remember: a maximum is simply a minimum
' with a negative attitude!
'''''''''''''''''''''''''''''''''''''''''
' machine epsilon
LOCAL epsm = 2.23e-16
' golden number
LOCAL c = 0.38196601125
LOCAL iter as integer, d, e
LOCAL t2, p, q
local r, u, fu
LOCAL x, xm, w
local v, fx, fw
LOCAL tol1, fv
x = a + c * (b - a)
w = x
v = w
e = 0.0
p = 0.0
q = 0.0
r = 0.0
sefunc(x, fx)
fw = fx
fv = fw
for iter = 1 to 100
print ("error in function minima!")
print ("(more than 50 iterations)")
xm = 0.5 * (a + b)
tol1 = tolm * abs(x) + epsm
t2 = 2.0 * tol1
if (abs(x - xm) <= (t2 - 0.5 * (b - a))) then
xmin = x
fmin = fx
exit sub
end if
if (abs(e) > tol1) then
r = (x - w) * (fx - fv)
q = (x - v) * (fx - fw)
p = (x - v) * q - (x - w) * r
q = 2.0 * (q - r)
if (q > 0.0) then
q = abs(q)
r = e
e = d
end if
if ((abs(p) >= abs(0.5 * q * r)) or (p <= q * (a - x)) or (p >= q * (b - x))) then
if (x >= xm) then
d = c * e
else
d = p / q
u = x + d
if ((u - a) < t2) or ((b - u) < t2) then
end if
if (abs(d) >= tol1) then
u = x + d
else
u = x + sgn(d) * tol1
end if
sefunc(u, fu)
if (fu <= fx) then
if (u >= x) then
v = w
fv = fw
w = x
fw = fx
x = u
fx = fu
else
if (u < x) then
if ((fu <= fw) Or (w = x)) then
fv = fw
w = u
fw = fu
fv = fu
end if
end sub
''''''''''''''''''''''''''''''''''''''''''''''''''''
''''''''''''''''''''''''''''''''''''''''''''''''''''
sub broot(x1in, x2in, factor, dxmax, x1out, x2out)
' bracket a single root of a nonlinear equation
' input
' x1in = initial guess for first bracketing x value
' x2in = initial guess for second bracketing x value
' factor = acceleration factor (non-dimensional)
' dxmax = rectification interval
' output
' xout1 = final value for first bracketing x value
' xout2 = final value for second bracketing x value
''''''''''''''''''''''''''''''''''''''''''''''''''''''''
LOCAL f1, f2
local x3, dx
' evaluate objective function at initial value
sefunc(x1in, f1)
' save initial value
x3 = x1in
' save initial delta-x
dx = x2in - x1in
' perform bracketing until the product of the
' two function values is negative
do
' geometrically accelerate the second point
x3 = x2in - dx
end if
x1out = x1in
x2out = x2in
END sub
''''''''''''''''''''''''''''''''''''''''''
''''''''''''''''''''''''''''''''''''''''''
sub brent(x1, x2, tol, xroot, froot)
' real root of a single non-linear function subroutine
' input
' x1 = lower bound of search interval
' x2 = upper bound of search interval
' tol = convergence criter%ia
' output
' xroot = real root of f(x) = 0
' froot = function value
' note: requires sub sefunc
'''''''''''''''''''''''''''''''
local eps, a, b
local c, d, e
local fa, fb, fcc
local tol1, xm, p
local q, r, s
local xmin, tmp
eps = 2.23e-16
e = 0.0
a = x1
b = x2
sefunc(a, fa)
sefunc(b, fb)
fcc = fb
for iter% = 1 to 50
c = a
fcc = fa
d = b - a
e = d
end if
if (abs(fcc) < abs(fb)) then
a = b
b = c
c = a
fa = fb
fb = fcc
fcc = fa
end if
tol1 = 2.0 * eps * abs(b) + 0.5 * tol
xm = 0.5 * (c - b)
if (abs(xm) <= tol1 or fb = 0.0) then exit for
if (abs(e) >= tol1 and abs(fa) > abs(fb)) then
s = fb / fa
if (a = c) then
q = 1.0 - s
r = fb / fcc
p = s * (2.0 * xm * q * (q - r) - (b - a) * (r - 1.0))
q = (q - 1.0) * (r - 1.0) * (s - 1.0)
if (p > 0.0) then q = -q
p = abs(p)
min = abs(e * q)
tmp = 3.0 * xm * q - abs(tol1 * q)
if (min < tmp) then min = tmp
if (2.0 * p < min) then
d = p / q
e = d
else
d = xm
e = d
end if
a = b
fa = fb
if (abs(d) > tol1) then
b = b + d
else
b = b + sgn(xm) * tol1
end if
sefunc(b, fb)
froot = fb
xroot = b
end sub
''''''''''''''''''''''''''''''''''''''''''
''''''''''''''''''''''''''''''''''''''''''
sub jbrent(x1, x2, tol, xroot, froot)
' real root of a single non-linear function subroutine
' input
' x1 = lower bound of search interval
' x2 = upper bound of search interval
' tol = convergence criter%ia
' output
' xroot = real root of f(x) = 0
' froot = function value
' note: requires sub jdfunc
'''''''''''''''''''''''''''''''
local eps, a, b
local c, d, e
local fa, fb, fcc
local tol1, xm, p
local q, r, s
local xmin, tmp, iter as integer
eps = 2.23e-16
e = 0.0
a = x1
b = x2
jdfunc(a, fa)
jdfunc(b, fb)
fcc = fb
for iter = 1 to 50
c = a
fcc = fa
d = b - a
e = d
end if
if (abs(fcc) < abs(fb)) then
a = b
b = c
c = a
fa = fb
fb = fcc
fcc = fa
end if
tol1 = 2.0 * eps * abs(b) + 0.5 * tol
xm = 0.5 * (c - b)
if (abs(xm) <= tol1 or fb = 0) then exit for
if (abs(e) >= tol1 and abs(fa) > abs(fb)) then
s = fb / fa
if (a = c) then
q = 1.0 - s
r = fb / fcc
p = s * (2.0 * xm * q * (q - r) - (b - a) * (r - 1.0))
q = (q - 1.0) * (r - 1.0) * (s - 1.0)
if (p > 0) then q = -q
p = abs(p)
xmin = abs(e * q)
tmp = 3.0 * xm * q - abs(tol1 * q)
if (xmin < tmp) then xmin = tmp
if (2.0 * p < xmin) then
d = p / q
e = d
else
d = xm
e = d
end if
a = b
fa = fb
if (abs(d) > tol1) then
b = b + d
else
b = b + sgn(xm) * tol1
end if
jdfunc(b, fb)
froot = fb
xroot = b
end sub
''''''''''''''''''''''''''''''''''''
''''''''''''''''''''''''''''''''''''
sub julian(month, day, year, jday)
' Gregorian date to julian day subroutine
' input
' month = calendar month
' day = calendar day
' year = calendar year (all four digits)
' output
' jday = julian day
' special notes
' (1) calendar year must include all digits
' (2) will report October 5, 1582 to October 14, 1582
' as invalid calendar dates and exit
'''''''''''''''''''''''''''''''''''''''''''''
local a, b, c, m, y
y = year
m = month
b = 0.0
c = 0.0
if (m <= 2.0) then
m = m + 12.0
if (y < 0.0) then c = -0.75
if (year < 1582.0) then
' null
elseif (year > 1582.0) then
b = 2.0 - a + fix(a / 4.0)
' null
elseif (month > 10.0) then
b = 2.0 - a + fix(a / 4.0)
' null
elseif (day > 14.0) then
b = 2.0 - a + fix(a / 4.0)
exit
jday = fix(365.25 * y + c) + fix(30.6001 * (m + 1.0)) + day + b + 1720994.5
end sub
'''''''''''''''''''''''''''''''''''
'''''''''''''''''''''''''''''''''''
sub gdate(jday, month, day, year)
' Julian day to Gregorian date subroutine
' input
' jday = julian day
' output
' month = calendar month
' day = calendar day
' year = calendar year
''''''''''''''''''''''''''''
local a, b, c, d, e, f, z, alpha
z = fix(jday + 0.5)
f = jday + 0.5 - z
if (z < 2299161) then
a = z + 1.0 + alpha - fix(alpha / 4.0)
b = a + 1524.0
c = fix((b - 122.1) / 365.25)
d = fix(365.25 * c)
e = fix((b - d) / 30.6001)
day = b - d - fix(30.6001 * e) + f
if (e < 13.5) then
if (month > 2.5) then
end sub
''''''''''''''''''''''''''''
''''''''''''''''''''''''''''
sub utc2tdb (jdutc, jdtdb)
' convert UTC julian date to TDB julian date
' input
' jdutc = UTC julian day
' tai_utc = TAI-UTC (seconds)
' output
' jdtdb = TDB julian day
' Reference Frames in Astronomy and Geophysics
' J. Kovalevsky et al., 1989, pp. 439-442
'''''''''''''''''''''''''''''''''''''''''''''
local corr, jdtt, t, leapsecond
' find current number of leap seconds
findleap(jdutc, leapsecond)
' compute TDT julian date
corr = (leapsecond + 32.184) / 86400.0
jdtt = jdutc + corr
' time argument for correction
t = (jdtt - 2451545.0) / 36525.0
' compute correction in microseconds
corr = 1656.675 * sin(dtr * (35999.3729 * t + 357.5287))
corr = corr + 22.418 * sin(dtr * (32964.467 * t + 246.199))
corr = corr + 13.84 * sin(dtr * (71998.746 * t + 355.057))
corr = corr + 4.77 * sin(dtr * ( 3034.906 * t + 25.463))
corr = corr + 4.677 * sin(dtr * (34777.259 * t + 230.394))
corr = corr + 10.216 * t * sin(dtr * (35999.373 * t + 243.451))
corr = corr + 0.171 * t * sin(dtr * (71998.746 * t + 240.98 ))
corr = corr + 0.027 * t * sin(dtr * ( 1222.114 * t + 194.661))
corr = corr + 0.027 * t * sin(dtr * ( 3034.906 * t + 336.061))
corr = corr + 0.026 * t * sin(dtr * ( -20.186 * t + 9.382))
corr = corr + 0.007 * t * sin(dtr * (29929.562 * t + 264.911))
corr = corr + 0.006 * t * sin(dtr * ( 150.678 * t + 59.775))
corr = corr + 0.005 * t * sin(dtr * ( 9037.513 * t + 256.025))
corr = corr + 0.043 * t * sin(dtr * (35999.373 * t + 151.121))
' convert corrections to days
corr = 0.000001 * corr / 86400.0
' TDB julian date
jdtdb = jdtt + corr
end sub
''''''''''''''''''''''''''''''''
''''''''''''''''''''''''''''''''
sub findleap(jday, leapsecond)
' find number of leap seconds for utc julian day
' input
' jday = utc julian day
' input via global
' jdleap = array of utc julian dates
' leapsec = array of leap seconds
' output
' leapsecond = number of leap seconds
''''''''''''''''''''''''''''''''''''''''''
local i as integer
if (jday <= jdleap(1)) then
' date is <= 1972; set to first data element
exit sub
if (jday >= jdleap(28)) then
' date is >= end of current data
' set to last data element
exit sub
' find data within table
for i = 1 to 27
leapsecond = leapsec(i)
exit sub
end if
end sub
''''''''''''''''''''''''
''''''''''''''''''''''''
sub jdfunc (jdutc, fx)
' objective function for tdb2utc
' input
' jdin = current value for UTC julian day
' output
' fx = delta julian day
''''''''''''''''''''''''''''
local jdwrk
utc2tdb(jdutc, jdwrk)
fx = jdwrk - jdsaved
end sub
''''''''''''''''''''
''''''''''''''''''''
function modulo(x)
' modulo 2 pi function
''''''''''''''''''''''''''
local a
a = x - pi2 * fix(x / pi2)
if (a < 0.0) then
modulo = a
end function
''''''''''''''''''''''
''''''''''''''''''''''
function atan3(a, b)
' four quadrant inverse tangent function
' input
' a = sine of angle
' b = cosine of angle
' output
' atan3 = angle (0 =< atan3 <= 2 * pi; radians)
''''''''''''''''''''''''''''''''''''''''''''''''''''
local c
if (abs(a) < 1.0e-10) then
exit function
if (abs(b) < 1.0e-10) then
exit function
end function
''''''''''''''''''''''
''''''''''''''''''''''
function vecmag(a())
' vector magnitude function
' input
' { a } = column vector ( 3 rows by 1 column )
' output
' vecmag = scalar magnitude of vector { a }
vecmag = sqr(a(1) * a(1) + a(2) * a(2) + a(3) * a(3))
end function
''''''''''''''''''''''''
''''''''''''''''''''''''
sub uvector (a(), b())
' unit vector subroutine
' input
' a = column vector (3 rows by 1 column)
' output
' b = unit vector (3 rows by 1 column)
'''''''''''''''''''''''''''''''''''''''''''
local i as integer, amag
amag = vecmag(a())
for i = 1 to 3
b(i) = a(i) / amag
else
b(i) = 0.0
end if
end sub
'''''''''''''''''''''''''
'''''''''''''''''''''''''
function vdot(a(), b())
' vector dot product function
' c = { a } dot { b }
' input
' n% = number of rows
' { a } = column vector with n rows
' { b } = column vector with n rows
' output
' vdot = dot product of { a } and { b }
''''''''''''''''''''''''''''''''''''''''''''
local c = 0.0
for i% = 1 to 3
vdot = c
end function
'''''''''''''''''''''''''''
'''''''''''''''''''''''''''
sub vcross(a(), b(), c())
' vector cross product subroutine
' { c } = { a } x { b }
' input
' { a } = vector a ( 3 rows by 1 column )
' { b } = vector b ( 3 rows by 1 column )
' output
' { c } = { a } x { b } ( 3 rows by 1 column )
c(1) = a(2) * b(3) - a(3) * b(2)
c(2) = a(3) * b(1) - a(1) * b(3)
c(3) = a(1) * b(2) - a(2) * b(2)
end sub
''''''''''''''''''''''''''''
''''''''''''''''''''''''''''
sub matxvec(a(), b(), c())
' matrix/vector multiplication subroutine
' { c } = [ a ] * { b }
' input
' a = matrix a ( 3 rows by 3 columns )
' b = vector b ( 3 rows )
' output
' c = vector c ( 3 rows )
''''''''''''''''''''''''''''''
local s, i%, j%
for i% = 1 to 3
for j% = 1 to 3
s = s + a(i%, j%) * b(j%)
next j%
c(i%) = s
end sub
''''''''''''''''''''''''''
''''''''''''''''''''''''''
sub transpose (a(), b())
' matrix traspose subroutine
' input
' m = number of rows in matrix [ a ]
' n = number of columns in matrix [ a ]
' a = matrix a ( 3 rows by 3 columns )
' output
' b = matrix transpose ( 3 rows by 3 columns )
'''''''''''''''''''''''''''''''''''''''''''''''''''
local i%, j%
for i% = 1 to 3
b(i%, j%) = a(j%, i%)
next j%
end sub
'''''''''''''''''''
'''''''''''''''''''
sub jd2str(jdutc)
' convert julian day to calendar date and UTC time
''''''''''''''''''''''''''''''''''''''''''''''''''''''
gdate (jdutc, cmonth, day, year)
print "calendar date ", month$(cmonth), " ", STR$(int(day)), " ", str$(year)
print " "
thr0 = 24.0 * (day - int(day))
thr = int(thr0)
tmin0 = 60.0 * (thr0 - thr)
tmin = int(tmin0)
tsec = 60.0 * (tmin0 - tmin)
print "UTC time ", str$(thr) + " hours " + str$(tmin) + " minutes " + str$(tsec, 0, 2) + " seconds"
end sub
'''''''''''''''''''''''
'''''''''''''''''''''''
sub deg2str(dd, dms$)
' convert decimal degrees to degrees,
' minutes, seconds string
' input
' dd = angle in decimal degrees
' output
' dms$ = string equivalent
'''''''''''''''''''''''''''''''
local d1, d, m, s
d1 = abs(dd)
d = fix(d1)
d1 = (d1 - d) * 60.0
m = fix(d1)
s = (d1 - m) * 60.0
if (dd < 0.0) then
d = -d
elseif (m <> 0.0) then
m = -m
else
s = -s
end if
dms$ = str$(d) + " deg " + str$(m) + " min " + str$(s, 0, 2) + " sec"
end sub